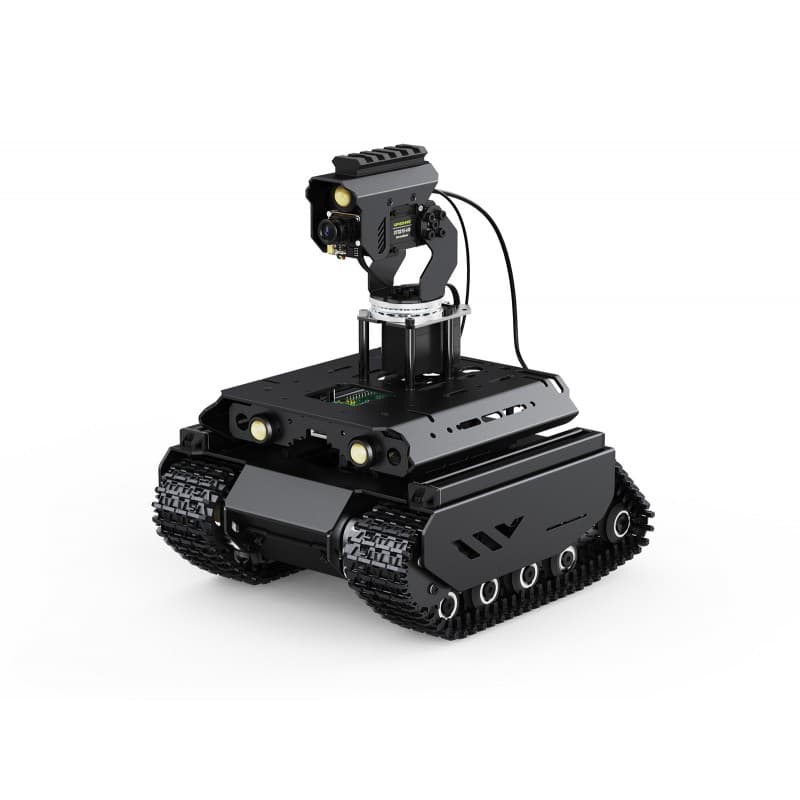
Waveshare UGV Beast
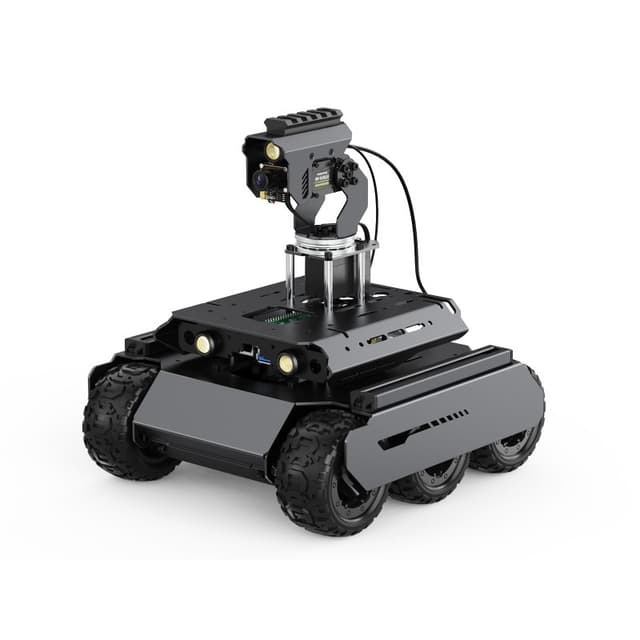
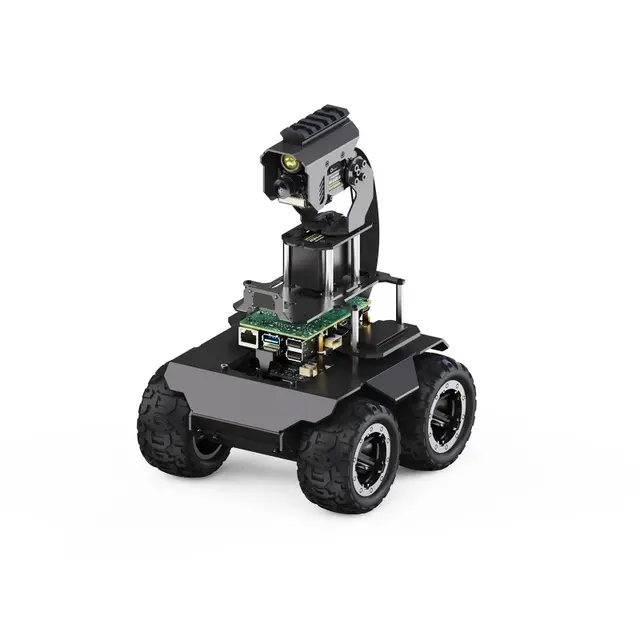
Open-source ROS2 AI robot with tracked chassis, Raspberry Pi 4B/5, ESP32 sub-controller, 5MP camera with pan-tilt, IMU, and support for LiDAR expansion. Programmable via Python, OpenCV, and ROS2.
$749.00
Tap any value to browse matching devices
Specifications
Components
Ultra-wide-angle camera with 160° field of view for computer vision tasks including object tracking, face detection, and gesture recognition
InvenSense ICM-20948 9-axis inertial measurement unit combining 3-axis accelerometer, gyroscope, and magnetometer for attitude sensing
ESP32 microcontroller handling motor PID control, sensor processing, and ESP-NOW multi-robot communication
Waveshare ST3215 servo with 30KG.CM torque powering the 2-axis pan-tilt camera module
Small OLED display for real-time robot status monitoring
Built-in microphone for audio input capabilities
Texas Instruments INA219 high-side current shunt and power monitor for battery voltage and current sensing
Bus Interfaces
Waveshare UGV Beast
The Waveshare UGV Beast is an open-source unmanned ground vehicle built around a tracked chassis with independent suspension. It combines a Raspberry Pi (4B or 5) as the main controller with an ESP32 for motion control and sensor processing.
Key Features
- ROS2 Humble LTS support on Debian Bookworm
- 5MP ultra-wide-angle camera with 160° FOV on a 2-axis pan-tilt module (ST3215 servo, 30KG.CM torque)
- Computer vision via OpenCV and MediaPipe: object tracking, face detection, gesture recognition
- ICM20948 9-axis IMU for attitude sensing
- WebRTC ultra-low latency video streaming via Flask web app
- ESP-NOW multi-robot communication with 100μs latency
- High-frequency PID closed-loop motor control
- Jupyter Lab interactive programming environment
- Multiple control methods: web app, keyboard (WASD), gamepad, Jupyter Lab
Expansion
- D500 LiDAR mounting capability
- 4G/5G module support
- 40-pin GPIO header for peripherals
- M2.5 mounting holes for accessories
Specifications
| Spec | Value |
|---|---|
| Main Controller | Raspberry Pi 4B (4GB) or Pi 5 |
| Sub Controller | ESP32 |
| Camera | 5MP, 160° FOV |
| IMU | ICM20948 (9-axis) |
| Pan-Tilt Servo | ST3215, 30KG.CM |
| Max Speed | 0.35 m/s |
| Track Width | 40mm |
| Turning Radius | 0m (in-situ rotation) |
| Battery | 3S UPS module (18650 cells, not included) |
| Dimensions (PT) | 232 × 197 × 252 mm |
| Weight (PT) | 2350 ± 5g |
Use Cases
6Robotics
General robotics applications including mobile robots, robotic arms, drones, and automated systems.
Education
Teaching programming, electronics, and computer science concepts. Popular in schools, universities, and coding bootcamps.
autonomous-vehicle
ros2
Computer Vision
Image recognition, object detection, and ML inference using embedded cameras and AI-capable processors.
ai
Where to Buy
Explore more of the directory — popular use cases, firmware, and specs to browse next.