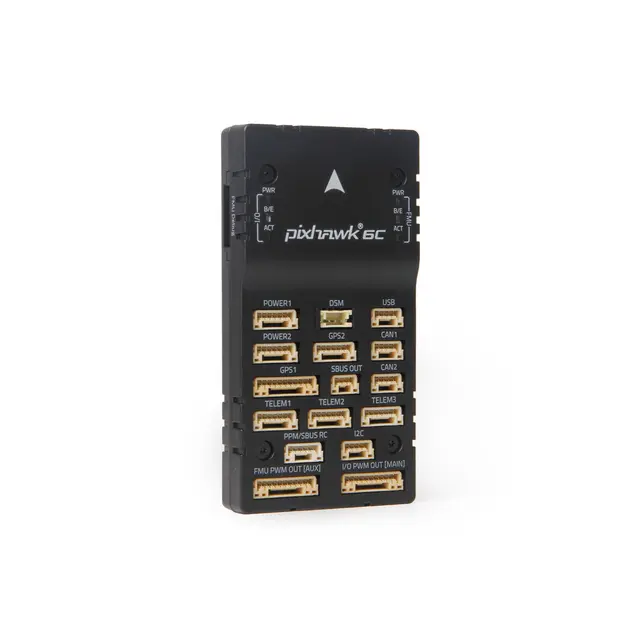
Holybro Pixhawk 6C
Flight ControllerOpen-source flight controller based on the Pixhawk FMUv6C standard. Features STM32H743 processor, dual redundant IMUs, barometer, and magnetometer. Runs ArduPilot or PX4 autopilot firmware.
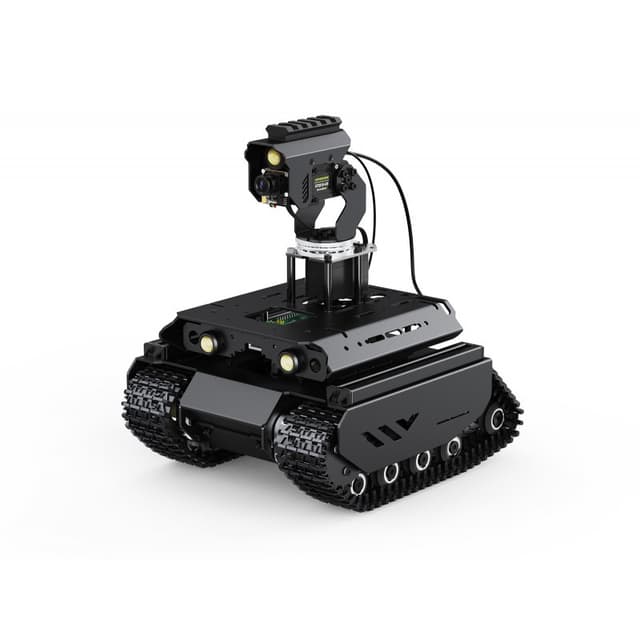
Waveshare UGV Beast
robotOpen-source ROS2 AI robot with tracked chassis, Raspberry Pi 4B/5, ESP32 sub-controller, 5MP camera with pan-tilt, IMU, and support for LiDAR expansion. Programmable via Python, OpenCV, and ROS2.
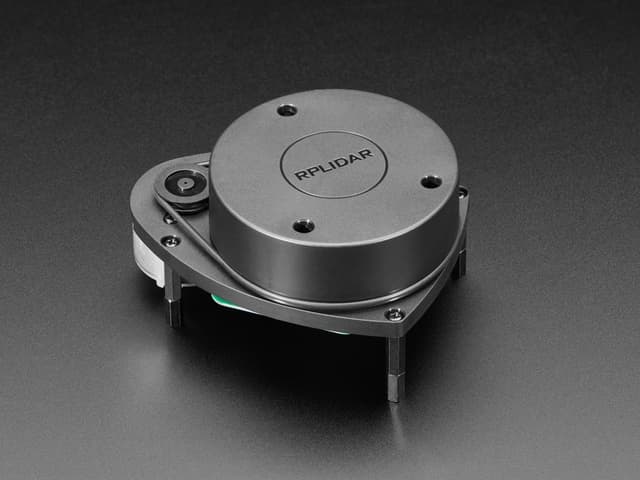
SLAMTEC RPLiDAR A1
Sensor Module360-degree 2D laser scanner with 12m range and 8000 samples per second. Widely used for ROS robotics, SLAM mapping, and autonomous navigation applications.
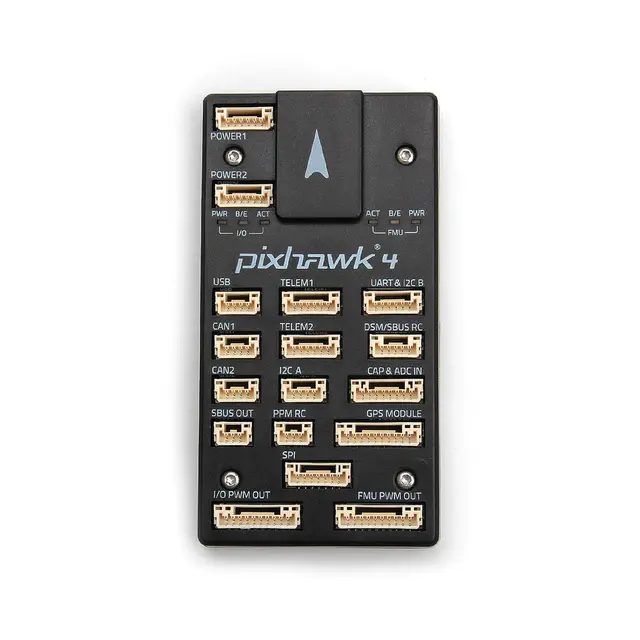
Holybro Pixhawk 4
Flight ControllerOpen-source flight controller based on the Pixhawk FMUv5 standard. Features STM32F765 processor at 216MHz, triple redundant IMUs, barometer, and magnetometer. Runs ArduPilot or PX4 autopilot firmware.
Get notified when new devices are added.
More to explore — popular traits shared by devices with Use Case: autonomous-vehicle.