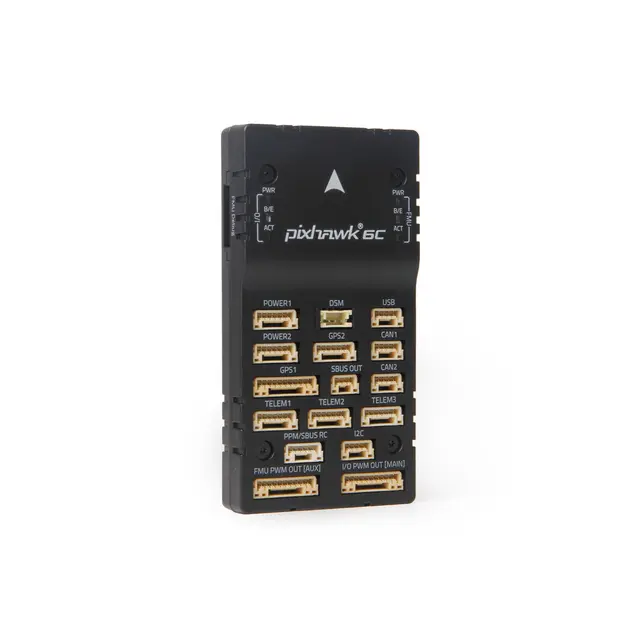
Holybro Pixhawk 4
Open-source flight controller based on the Pixhawk FMUv5 standard. Features STM32F765 processor at 216MHz, triple redundant IMUs, barometer, and magnetometer. Runs ArduPilot or PX4 autopilot firmware.
$124.99
Tap any value to browse matching devices
Specifications
Components
32-bit ARM Cortex-M7 @ 216MHz, 2MB flash, 512KB SRAM
IO co-processor, ARM Cortex-M3 @ 24MHz
6-axis accelerometer and gyroscope
6-axis accelerometer and gyroscope (redundant)
3-axis digital magnetometer for compass heading
High-resolution barometric pressure sensor for altitude estimation
Bus Interfaces
Holybro Pixhawk 4
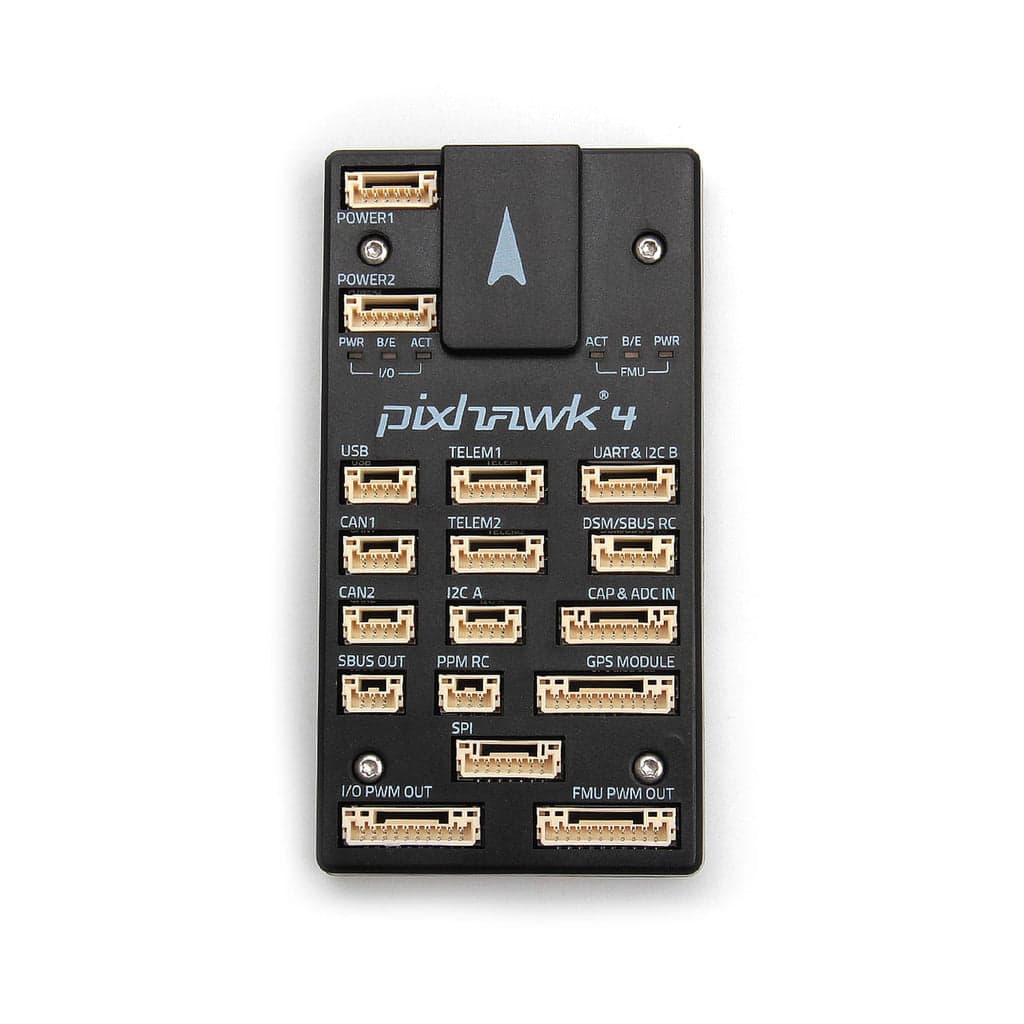
The Pixhawk 4 is an open-source flight controller designed and manufactured by Holybro, based on the Pixhawk FMUv5 open standard. It features a powerful STM32F765 main processor running at 216MHz with triple redundant IMU sensors for highly reliable flight performance.
Key Features
- Triple Redundant IMUs: ICM-20689, BMI055, and IST8310 sensors for reliable attitude estimation and failover
- High-Performance MCU: STM32F765 Cortex-M7 at 216MHz with 2MB flash and 512KB SRAM
- Dedicated IO Processor: STM32F100 Cortex-M3 handles failsafe I/O operations
- 16 PWM Servo Outputs: 8 from IO processor, 8 from FMU
- 2 CAN Buses: For DroneCAN peripherals
- Open Source: Full schematics, PCB layout, and firmware available under open-source licenses
Sensors
- IMU 1: ICM-20689 (accelerometer + gyroscope)
- IMU 2: BMI055 (accelerometer + gyroscope)
- Magnetometer: IST8310
- Barometer: MS5611
Interfaces
- 5 serial ports (UART/USART) including GPS and telemetry
- 2 CAN buses
- 1 I2C bus
- 1 SPI bus
- 16 PWM servo outputs (8 IO + 8 FMU)
- Dedicated R/C input (S.BUS, Spektrum/DSM, CPPM)
- Dedicated S.BUS output
- 2 analog power input ports
- USB-C connector
- MicroSD card slot for logging
Power
- Input voltage: 4.9-5.5V (via power module)
- USB power: 4.75-5.25V
- Servo rail: 0-36V
- Operating temperature: -25 to 85°C
Physical
- Dimensions: 44 x 84 x 12mm
- Weight: 33.3g (plastic case) / 49g (aluminum case)
Firmware
Compatible with both major open-source autopilot stacks:
- PX4: Full support as a reference platform
- ArduPilot: Full support for Copter, Plane, and Rover
Use Cases
5Resources
Where to Buy
Explore more of the directory — popular use cases, firmware, and specs to browse next.