Build Guideintermediate
TinkerNav RTK Rover and Base Station Firmware
Official open-source firmware for TinkerNav RTK GNSS boards, enabling both RTK rover and base station modes with WiFi, LoRa, and NTRIP correction data support via ESP32-S3 and SkyTraq PX1125R.
Boards:ESP32-S3RP2040
Firmware:Arduino
Use Cases:GPS TrackingRobotics
Overview
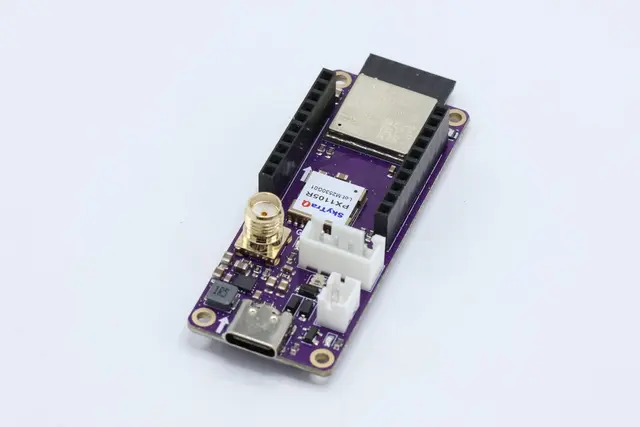
The TinkerNav firmware is the official open-source software for Tinkerbug Robotics' TinkerNav RTK GNSS base board. It transforms the TinkerNav hardware into either an RTK rover or base station, providing centimeter-level GPS positioning accuracy.
Key Features
- Dual Mode Operation: Configure as either an RTK base station (generating RTCM corrections) or rover (receiving corrections for precise positioning)
- Multiple Communication Methods: Supports WiFi, LoRa, ESPNow, and cellular (SIM7000) for transmitting correction data
- NTRIP Support: Connect to internet-based NTRIP casters for correction data
- Arduino IDE Compatible: Flash firmware using Arduino IDE via USB-C
- Auto-Configuration: The PX1125R GNSS receiver configures automatically through binary messages from the ESP32-S3
- Web Interface: Access rover status through a built-in web server on any WiFi-enabled device
Hardware
- TinkerNav base board (ESP32-S3 + SkyTraq PX1125R/PX1122R GNSS receiver + RP2040)
- GNSS antenna (L1/L2/L5 multi-band)
- Optional: TinkerSend LoRa, TinkerSend Mobile, TinkerCharge battery module
Getting Started
- Download the firmware from the GitHub repository
- Open in Arduino IDE (1.8.x or 2.x)
- Install dependencies (AdaFruit NeoPixel, Tinkerbug libraries)
- Connect TinkerNav via USB-C and flash