madflight FC3v2 RP2350B Flight Controller
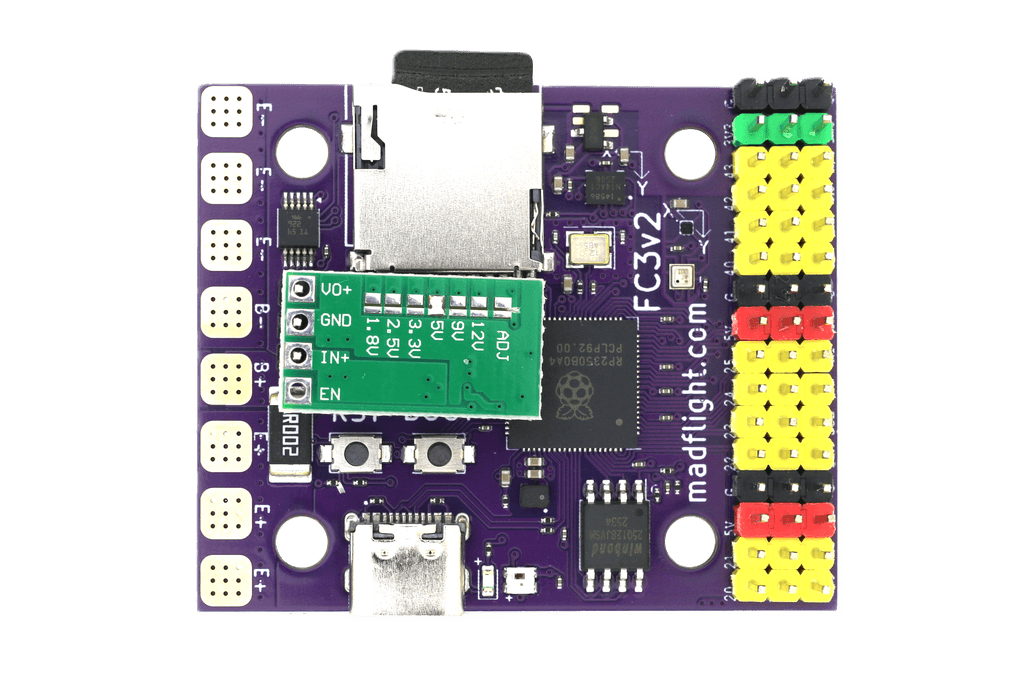
Open-source flight controller board with RP2350B MCU, 10-DOF sensor suite (gyro, accelerometer, barometer, magnetometer), INA226 battery monitor, microSD with 4-bit SDIO, and DC-DC converter. 50.7x41.6mm, 6.3g.
$29.00
Tap any value to browse matching devices
Specifications
Components
Raspberry Pi RP2350B with dual ARM Cortex-M33 or dual Hazard3 RISC-V cores at 150MHz, 520KB SRAM, 48 GPIO pins in QFN-80 package
STMicroelectronics high-performance 6-axis IMU with accelerometer and gyroscope, sensor fusion core, and machine learning core
Bosch Sensortec high-precision barometric pressure sensor with 2cm altitude noise at 85Hz output data rate, ideal for drone altitude hold
MEMSIC 3-axis magnetic sensor with 20-bit resolution, 0.0625mG per LSB sensitivity, 2mG RMS noise, and 1-degree heading accuracy
Texas Instruments 16-bit digital current and power monitor with I2C interface, measuring up to 36V at 1.25mV resolution and 40A at 1.25mA resolution
Worldsemi addressable RGB LED with integrated driver for visual status indication and programmable lighting effects
Bus Interfaces
GPIO Map
The madflight FC3v2 is a fully open-source flight controller board built around the Raspberry Pi RP2350B microcontroller. Designed in Zurich, Switzerland, it packs a complete 10-DOF sensor suite into a compact 50.7 x 41.6 mm form factor weighing just 6.3 grams. The board integrates an LSM6DSV16B 6-axis IMU (gyroscope and accelerometer), BMP580 barometric pressure sensor with 2cm altitude noise at 85Hz, and MMC5603NJ 3-axis magnetometer with 20-bit resolution for precise heading information. An INA226 battery monitor provides 16-bit current and voltage measurement up to 36V and 40A with 1.25mV/1.25mA resolution.
The RP2350B processor offers 48 GPIO pins, of which 30 are accessible via standard 2.54mm pin headers. The board exposes 22 PWM-capable pins, 8 DSHOT outputs for brushless motor ESCs, 6 serial ports (2 hardware UART plus 4 PIO UART), I2C, SPI, and 4 ADC channels. A microSD card slot with fast 4-bit SDIO interface enables high-speed flight data logging, and a WS2812B RGB LED provides visual status indication. The optional SO-8 socket accommodates additional PSRAM or flash memory.
Power flexibility is a key strength of the FC3v2. It can run directly from 3V to 5.5V via USB or a 1S LiPo battery, or use the included DC-DC converter module for 6.5 to 20V input (2S to 4S battery packs) with 5V 2A continuous output. The DC-DC converter measures just 20 x 10 x 5 mm and weighs 1.8 grams, mountable on top or bottom of the main board. Standard 30.5 x 30.5 mm mounting holes with vibration-dampening grommets make integration into drone frames straightforward.
The board runs the madflight open-source firmware, an Arduino/PlatformIO toolbox for building flight controllers with full PID stabilization for quadcopters and fixed-wing aircraft. Betaflight support is also in development with DSHOT600 already functional. All hardware design files, schematics, and source code are available under the MIT license on GitHub.
Use Cases
5Drone Flight Controller
Flight controller for drones, quadcopters, and multirotor aircraft with PID stabilization and motor control
RC Aircraft
Radio-controlled airplane and fixed-wing aircraft flight control and stabilization
Robotics
General robotics applications including mobile robots, robotic arms, drones, and automated systems.
Orientation Sensing
Orientation and motion sensing applications using IMU, magnetometer, and barometer sensor fusion
Data Logging
Recording time-stamped sensor readings, environmental data, or system events to local storage.
Resources
Where to Buy
Explore more of the directory — popular use cases, firmware, and specs to browse next.