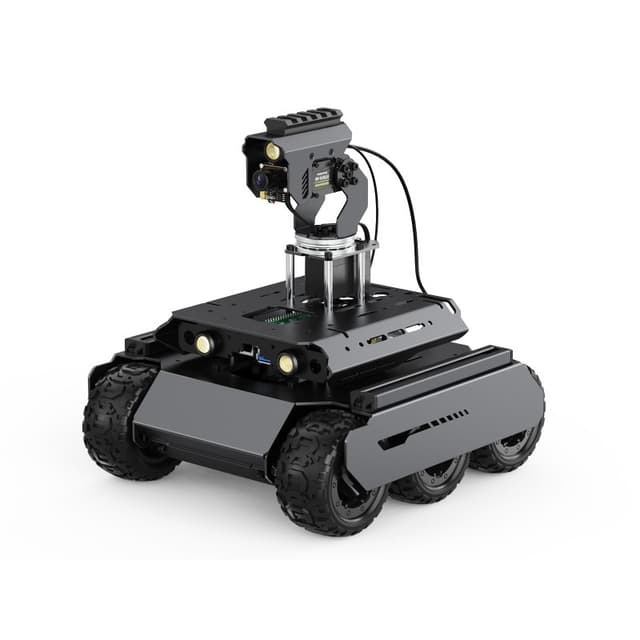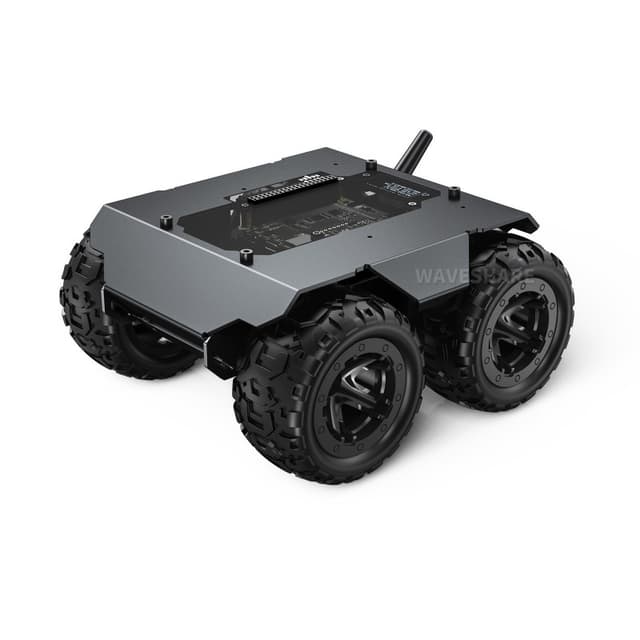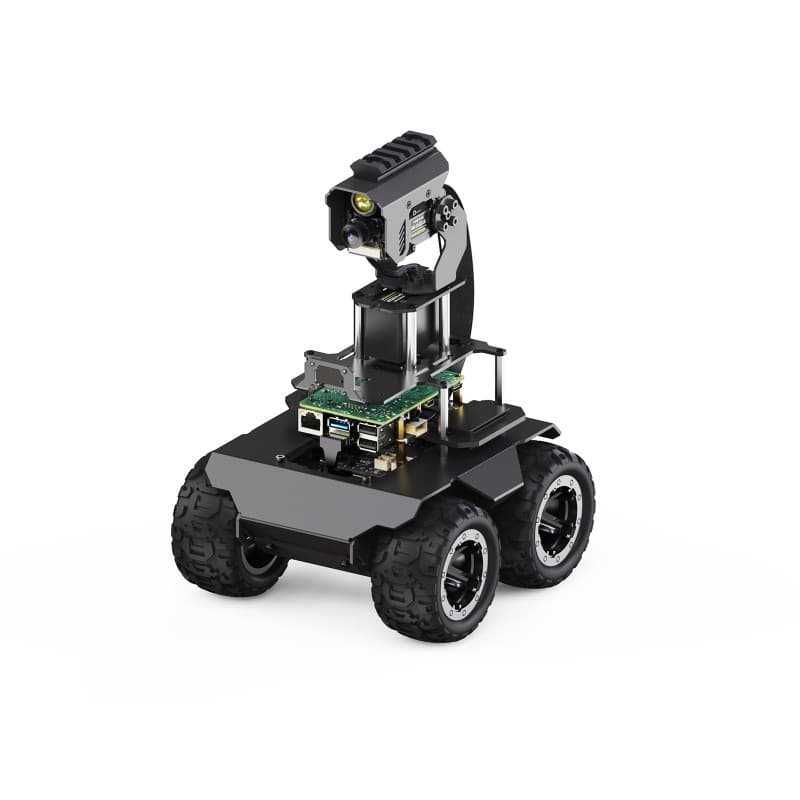
Waveshare RaspRover
Open-source 4WD AI robot with dual-controller architecture (ESP32 + Raspberry Pi), 5MP 160-degree camera, pan-tilt module, audio system, computer vision via OpenCV/MediaPipe, and ROS2 support for AI robotics education.
$174.99
Tap any value to browse matching devices
Specifications
Components
Dual-core WiFi & Bluetooth sub-controller for motion and sensor processing
Dual H-bridge MOSFET motor driver for 4 N20 encoder motors
9-axis IMU (accel + gyro + magnetometer) for motion sensing and stabilization
I2C voltage/current/power monitor for battery management
USB audio controller IC for speaker and microphone
Audio amplifier for dual-track speaker output
4-port USB 2.0 hub controller for peripheral management
USB-to-serial converter for LIDAR UART data
Serial bus servo for pan-tilt, 20 kg.cm torque (PT versions)
5MP ultra-wide-angle camera with 160 degree FOV for computer vision
Bus Interfaces
GPIO Map
Waveshare RaspRover
The Waveshare RaspRover is an open-source 4WD AI robot designed for robotics education and AI application development. It uses the same dual-controller architecture as its larger sibling, the UGV Rover, pairing an ESP32 sub-controller with a Raspberry Pi 4B or 5 host computer in a more compact form factor.
Dual-Controller Architecture
The ESP32 handles real-time motion control with PID closed-loop speed regulation for four N20 encoder motors, while processing data from the ICM-20948 9-axis IMU and INA219 battery monitor. The Raspberry Pi runs Debian Bookworm with ROS2 Humble LTS, handling computer vision, web serving, and AI workloads.
Vision & Audio System
The 5MP camera (160-degree FOV) connects via CSI on Pi 4B or USB on Pi 5. An optional 2-DOF pan-tilt module with ST3215 bus servos (20 kg.cm torque) provides camera articulation with IMU-based stabilization. The onboard audio system includes an SSS1629A5 USB audio controller, APA2068 amplifier, dual-track speaker output, and integrated microphone, enabling voice interaction applications.
Computer Vision
OpenCV and MediaPipe power the vision pipeline: color recognition and targeting, face detection with automatic photo/video capture, multi-object recognition, gesture recognition, and vision-based line tracking for autonomous driving. All features are accessible through a Flask-based web application with WebRTC video streaming.
Communication
WiFi and Bluetooth from the ESP32, plus ESP-NOW for robot-to-robot coordination with approximately 100-microsecond latency. The web control interface requires no software installation. A wireless gamepad is included for manual control.
Power & Expansion
A 3S UPS module runs on three 18650 batteries (sold separately) with simultaneous charge/discharge capability. The 40-pin GPIO header connects to the Raspberry Pi (UART preserved), with additional I2C expansion interfaces, bus servo ports, and mounting compatibility for D500/STL27L LIDAR modules and 4G/5G cellular expansion.
Use Cases
6Mobile Robot
Wheeled or tracked robot platforms for navigation, obstacle avoidance, and autonomous driving.
Computer Vision
Image recognition, object detection, and ML inference using embedded cameras and AI-capable processors.
autonomous-navigation
stem-kit
Voice Assistant
Offline and cloud-connected voice assistant, wake-word detection, and speech recognition projects.
ros2-robot
Resources
Where to Buy
Available Software
2Explore more of the directory — popular use cases, firmware, and specs to browse next.