Waveshare RoArm-M3
ESP32-based 5+1 DOF robotic arm with 1kg payload, 360-degree base, dual-drive shoulder, 7 servos, 9-axis IMU, TF card slot, and ROS 2 + LeRobot support. Carbon fiber and aluminum build.
$239.99
Tap any value to browse matching devices
Specifications
Components
Espressif ESP32 dual-core Xtensa LX6 microcontroller with integrated WiFi and Bluetooth
Feetech ST3215 and ST3215-HS TTL serial bus servos with 30kg.cm torque at 12V, 40rpm no-load speed, and 12-bit magnetic encoder
QST QMI8658C 6-axis inertial measurement unit with 3-axis accelerometer and 3-axis gyroscope
AKM AK09918C 3-axis electronic compass for orientation sensing
Texas Instruments INA219 high-side current and power monitor with I2C interface
Toshiba TB6612FNG dual H-bridge motor driver for DC and stepper motor control
0.91-inch OLED screen for real-time status and parameter display
Bus Interfaces
Overview
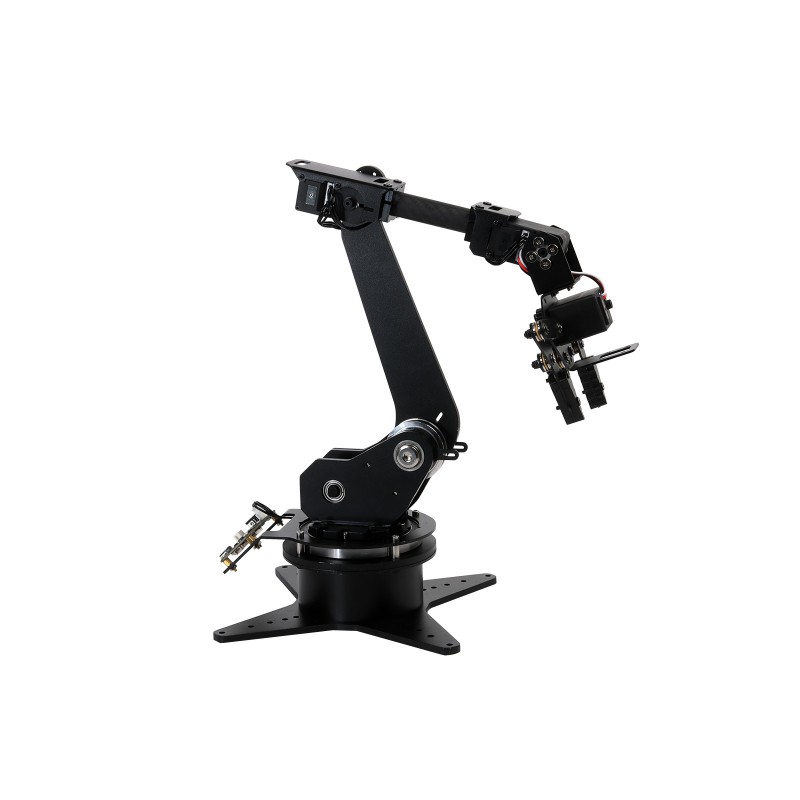
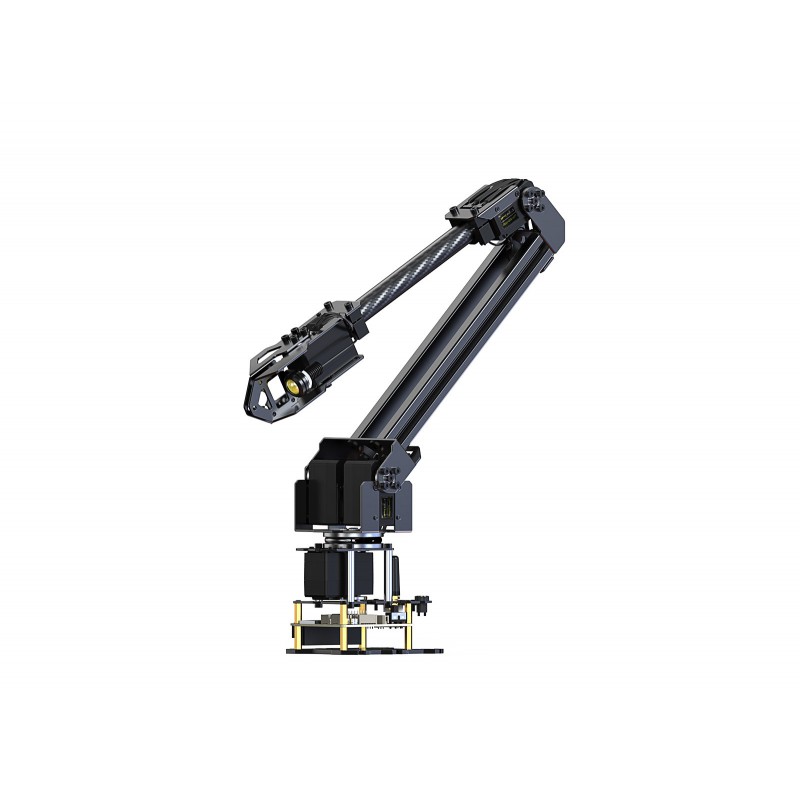
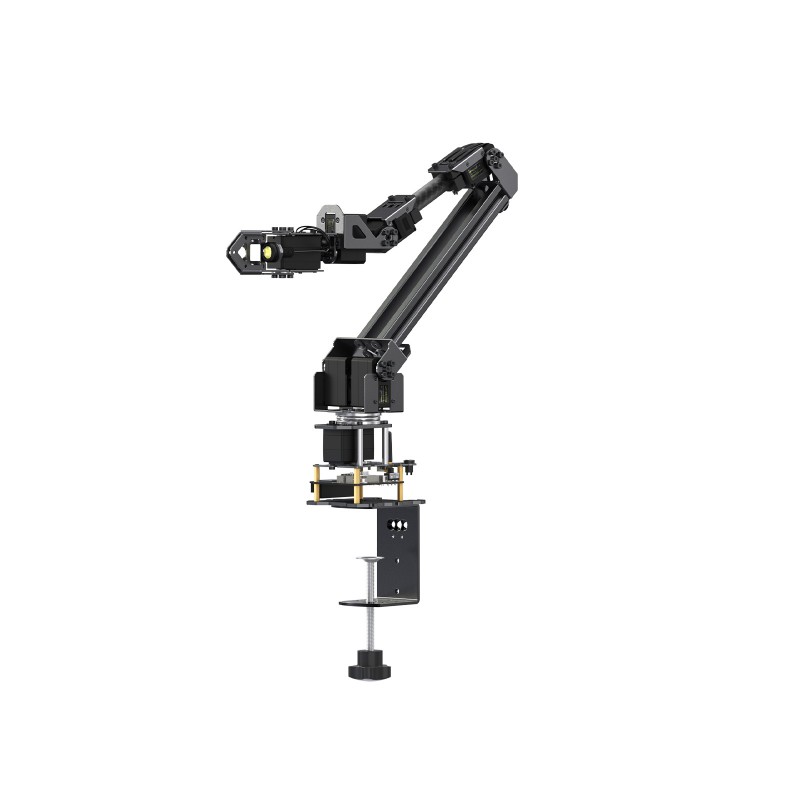
The Waveshare RoArm-M3 is an advanced 5+1 DOF desktop robotic arm featuring 7 high-torque serial bus servos, a 2-DOF wrist joint with pitch and horizontal rotation, and a 360-degree omnidirectional base. Built with carbon fiber and aluminum, it handles a 1kg payload with a workspace diameter of over 1.1 meters.
Key Features
- 5+1 Degrees of Freedom: 5 flexible joints plus gripper/end-of-arm tooling
- 2-DOF Wrist Joint: Pitch and horizontal rotation for complex manipulation
- 1kg Payload Capacity at full extension with ±5mm repositioning precision
- 360-Degree Base Rotation: Omnidirectional workspace coverage
- Dual-Drive Shoulder Technology: Enhanced torque and stability
- Dynamic External Force Adaptive (DEFA) Control: Real-time force response
- 12-bit Magnetic Encoders: 0.088-degree feedback precision
- 9-Axis IMU: QMI8658C motion sensor + AK09918C compass
- TF Card Slot: On-board data logging
- LIDAR Interface: Type-C LADAR port for environment scanning
- Table Clamp Mount: Supports up to 72mm table edge thickness
Specifications
| Parameter | Value |
|---|---|
| DOF | 5+1 |
| Servos | 7x ST3215/ST3215-HS (30kg.cm @ 12V) |
| Servo Speed | 40 RPM (no-load) |
| Workspace | 1120mm horizontal, 798mm vertical |
| Weight | 973.5g ± 15g (M3-S) / 1020.8g ± 15g (M3-Pro) |
| Power | 12V 5A DC |
| Battery | 3S Lithium compatible |
| Payload | 1kg |
Joint Ranges
- Base: 360 degrees
- Shoulder: 180 degrees
- Elbow: 225 degrees
- Hand (Gripper mode): 135 degrees
- Hand (Wrist mode): 270 degrees
Connectivity
- WiFi 2.4GHz (AP mode: "RoArm-M3" / STA mode)
- Bluetooth 4.2
- ESP-NOW for lead-follow multi-arm setups
- USB Type-C (UART @ 115200 baud)
- I2C expansion interface
- 40-pin GPIO header for Raspberry Pi / Jetson Nano
- IPEX Gen 1 antenna interface
- LIDAR Type-C port
Development
Supports Arduino IDE, ESP-IDF, ROS 2 with URDF model files, and Hugging Face LeRobot framework for AI-driven manipulation tasks. Open-source control code with JSON command protocol over HTTP or serial. Python desktop software available for direct control.
Variants
- RoArm-M3-S: Standard version ($239.99)
- RoArm-M3-Pro: Upgraded with all-metal servos ($339.99)
Use Cases
6Robotics
General robotics applications including mobile robots, robotic arms, drones, and automated systems.
robotic-arm
automation
Education
Teaching programming, electronics, and computer science concepts. Popular in schools, universities, and coding bootcamps.
pick-and-place
3d-printing-companion
Where to Buy
Explore more of the directory — popular use cases, firmware, and specs to browse next.