Waveshare RoArm-M2-S
ESP32-based 4-DOF robotic arm with 360-degree base rotation, 500g payload at 300mm reach, dual-drive shoulder joint, 9-axis IMU, and ROS 2 + LeRobot compatibility. Under 850g total weight.
$189.99
Tap any value to browse matching devices
Specifications
Components
Espressif ESP32 dual-core Xtensa LX6 microcontroller with integrated WiFi and Bluetooth
Feetech ST3215 TTL serial bus servo with 30kg.cm torque at 12V, 40rpm no-load speed, and 12-bit magnetic encoder
QST QMI8658C 6-axis inertial measurement unit with 3-axis accelerometer and 3-axis gyroscope
AKM AK09918C 3-axis electronic compass for orientation sensing
Texas Instruments INA219 high-side current and power monitor with I2C interface
Toshiba TB6612FNG dual H-bridge motor driver for DC and stepper motor control
0.91-inch OLED screen for real-time status and parameter display
Bus Interfaces
Overview
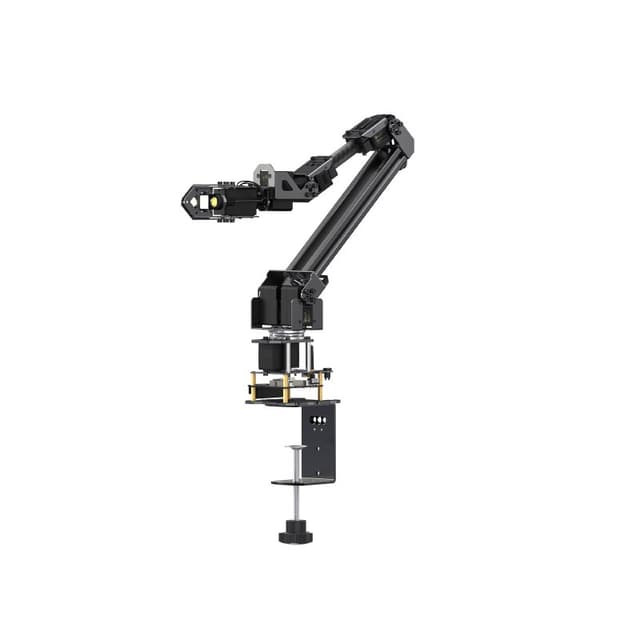
The Waveshare RoArm-M2-S is a lightweight 4-DOF desktop robotic arm featuring a 360-degree omnidirectional base, dual-drive shoulder joint technology, and an ESP32-WROOM-32 controller. Weighing under 850g, it delivers a 500g payload capacity at 300mm reach with a workspace diameter of over 1 meter.
Key Features
- 4 Degrees of Freedom with 360-degree base rotation
- Dual-Drive Shoulder Joint: Innovative technology for enhanced torque and stability
- 500g Payload at 300mm reach with ±4mm repositioning precision
- 12-bit Magnetic Encoders: 0.088-degree feedback precision on all joints
- Dynamic External Force Adaptive (DEFA) Control: Responds to external forces in real-time
- 9-Axis IMU: AK09918C 3-axis compass + QMI8658C 6-axis motion sensor
- INA219 Power Monitoring: Real-time voltage and current sensing
- Cross-Platform Web App: Browser-based control with no installation required
- Task Recording: One-click automatic recording and JSON-based playback
Specifications
| Parameter | Value |
|---|---|
| DOF | 4 |
| Servos | 5x ST3215 (30kg.cm @ 12V) |
| Servo Speed | 40 RPM (no-load) |
| Workspace | 1090mm horizontal, 798mm vertical |
| Weight | 826g ± 15g |
| Power | 12V 5A DC |
| Battery | 3S Lithium compatible |
Joint Ranges
- Base: 360 degrees
- Shoulder: 180 degrees
- Elbow: 180 degrees
- End Effector (Gripper): 135 degrees
- End Effector (Wrist): 270 degrees
Connectivity
- WiFi 2.4GHz (AP mode: "RoArm-M2", STA mode supported)
- ESP-NOW for lead-follow multi-arm control
- USB Type-C (UART serial)
- I2C expansion interface
- 40-pin GPIO header for Raspberry Pi / Jetson Nano integration
- LIDAR interface support
Development
Compatible with Arduino IDE, ESP-IDF, ROS 2 Humble with MoveIt2, and Python scripting via UART or HTTP. Open-source control code and JSON command protocol. URDF model files provided for simulation.
Variants
- RoArm-M2-S: Standard version with plastic servo housings ($189.99)
- RoArm-M2-Pro: Upgraded with all-metal ST3235 bus servos ($299.99)
Use Cases
6Robotics
General robotics applications including mobile robots, robotic arms, drones, and automated systems.
robotic-arm
automation
Education
Teaching programming, electronics, and computer science concepts. Popular in schools, universities, and coding bootcamps.
pick-and-place
3d-printing-companion
Resources
Where to Buy
Explore more of the directory — popular use cases, firmware, and specs to browse next.