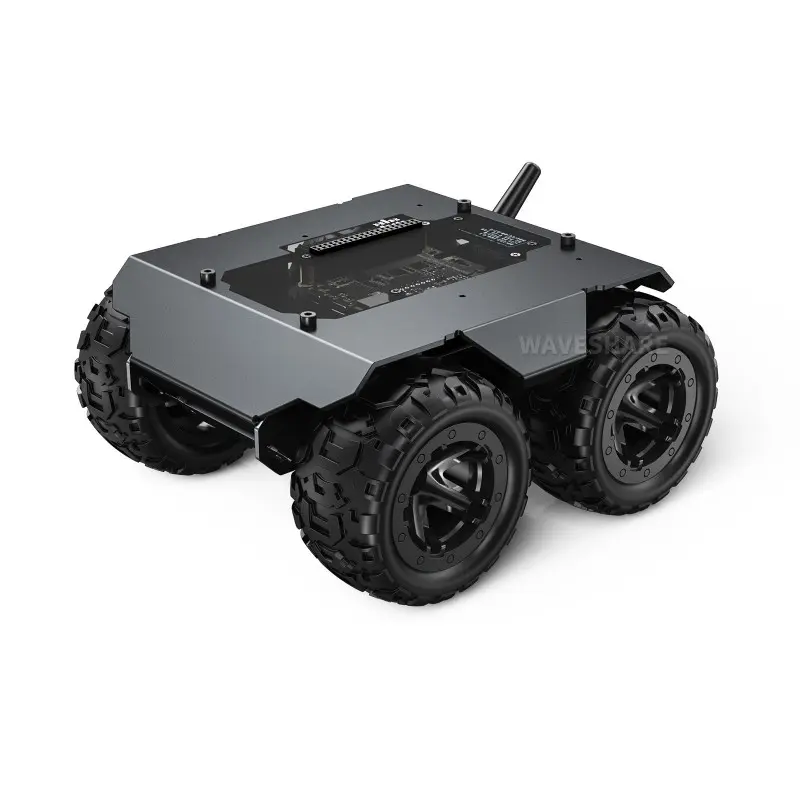
Waveshare WAVE ROVER
Flexible 4WD mobile robot chassis with all-metal body, ESP32 controller, 0.91\" OLED, 9-axis IMU, 3S UPS power system, and open-source firmware. Supports Raspberry Pi and Jetson Nano as host computers.
$89.99
Tap any value to browse matching devices
Specifications
Components
Dual-core WiFi & Bluetooth sub-controller for motion and sensor processing
Dual H-bridge MOSFET motor driver for 4 N20 geared motors
6-axis IMU (accelerometer + gyroscope) for motion sensing
3-axis electronic compass for heading detection
I2C voltage/current/power monitor for battery management
USB-to-UART bridge for programming and LIDAR data
0.91-inch 128x32 OLED display for status monitoring
N20 geared motor, 12V rated, 200 RPM, 0.7 kg.cm stall torque (x4)
Bus Interfaces
GPIO Map
Waveshare WAVE ROVER
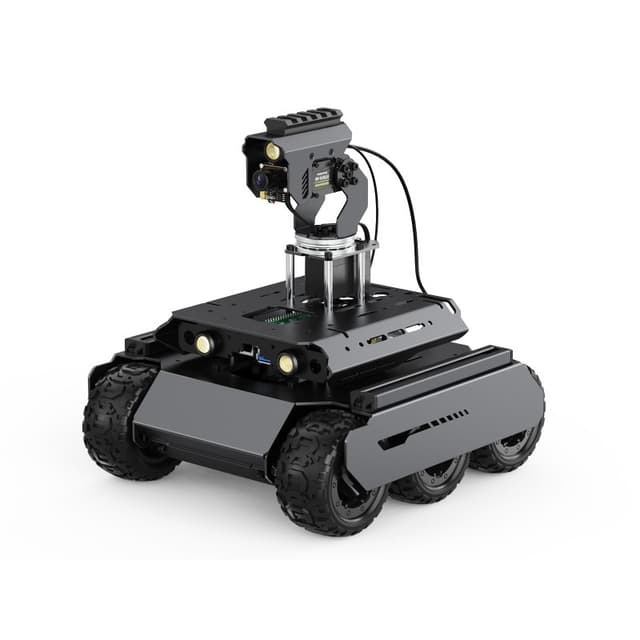
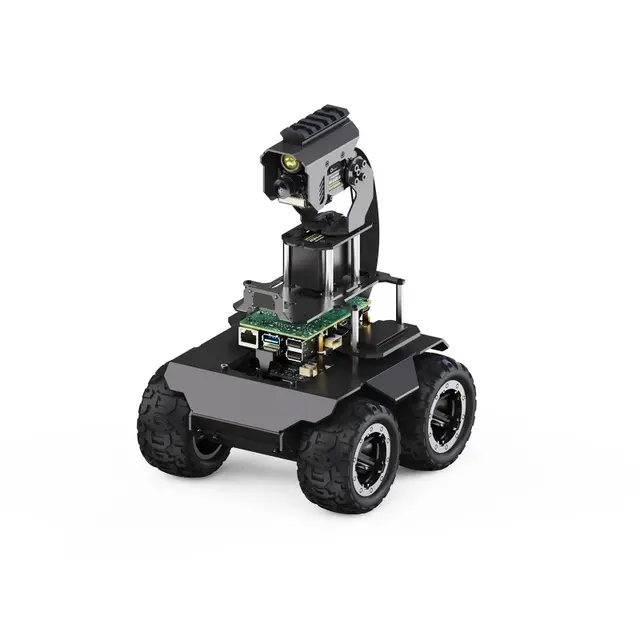
The Waveshare WAVE ROVER is a compact, all-metal 4WD mobile robot chassis designed as a versatile base platform for robotics projects. Built around an ESP32-based driver board, it provides WiFi and Bluetooth connectivity, motor control, sensor fusion, and expansion interfaces out of the box.
Chassis Design
The chassis uses 2mm thick 5052 aluminum alloy construction with an upper surface area of 17,551 mm squared. Four rubber-tired nylon-hub wheels (80mm diameter, 42.5mm width) driven by N20 12V geared motors (GF12-N20, 200 RPM) deliver a top speed of 1.25 m/s with zero-radius turning capability. The platform handles 22-degree inclines, clears 40mm vertical obstacles, and carries up to 0.8 kg payload.
Electronics
The onboard ESP32 driver board (General Driver for Robots) includes a TB6612FNG dual H-bridge motor driver, QMI8658C 6-axis IMU with AK09918C magnetometer (9-axis total), INA219 battery monitor, 0.91-inch OLED display, CP2102 USB-UART bridges, and a TF card slot. Communication options include WiFi AP/STA mode, Bluetooth, ESP-NOW, UART, I2C, and serial bus servo control.
Power System
A built-in 3S UPS module accepts three 18650 lithium-ion batteries (sold separately), providing regulated 5V and 3.3V outputs. The system supports simultaneous charging and discharging via the included 12.6V 2A power supply, with real-time voltage and current monitoring through the INA219.
Host Computer Support
The mounting plate accommodates Raspberry Pi 4B, Jetson Nano, Jetson Orin Nano, and Raspberry Pi Zero. A 40-pin header provides UART communication between the ESP32 and the host. Additional mounting points support LD19/STL-27L LIDAR modules and pan-tilt camera systems.
Software
All firmware is open-source and supports Arduino IDE development. The ESP32 runs a web server for WiFi-based control, supports ESP-NOW for multi-robot communication, and provides JSON-based command interfaces over UART for host computer integration.
Use Cases
4Resources
Where to Buy
Available Software
1Explore more of the directory — popular use cases, firmware, and specs to browse next.