ESP-NOW
7 devices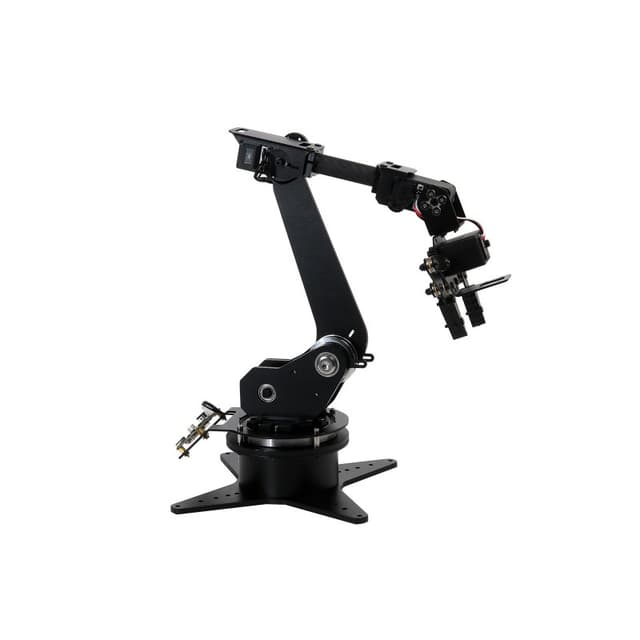
Waveshare RoArm-M1
Robotic ArmESP32-based 5-DOF desktop robotic arm with high-torque serial bus servos, WiFi/Bluetooth control, motion recording, inverse kinematics, and ROS 2 support. Carbon fiber and aluminum construction.
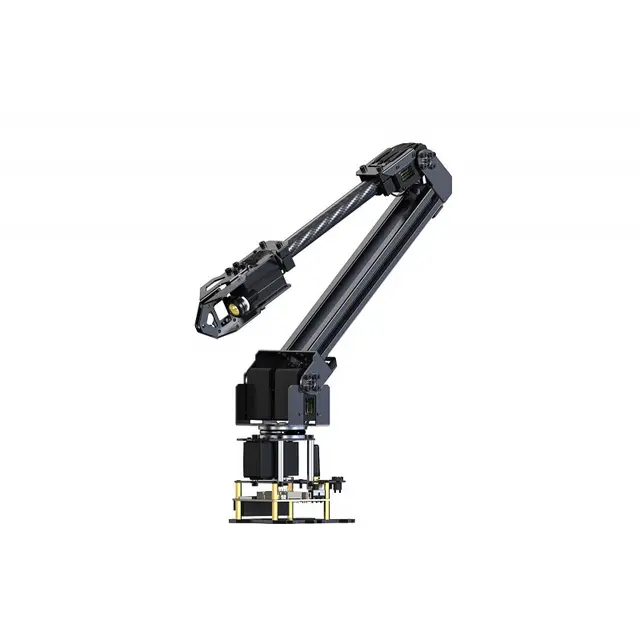
Waveshare RoArm-M2-S
Robotic ArmESP32-based 4-DOF robotic arm with 360-degree base rotation, 500g payload at 300mm reach, dual-drive shoulder joint, 9-axis IMU, and ROS 2 + LeRobot compatibility. Under 850g total weight.
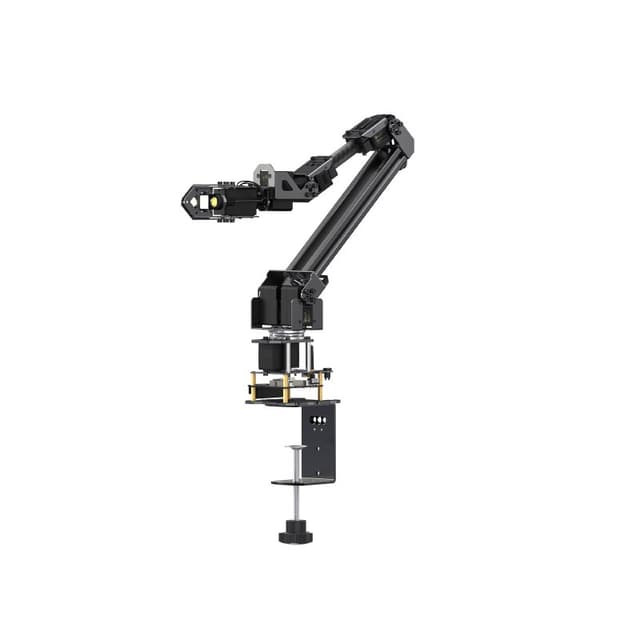
Waveshare RoArm-M3
Robotic ArmESP32-based 5+1 DOF robotic arm with 1kg payload, 360-degree base, dual-drive shoulder, 7 servos, 9-axis IMU, TF card slot, and ROS 2 + LeRobot support. Carbon fiber and aluminum build.
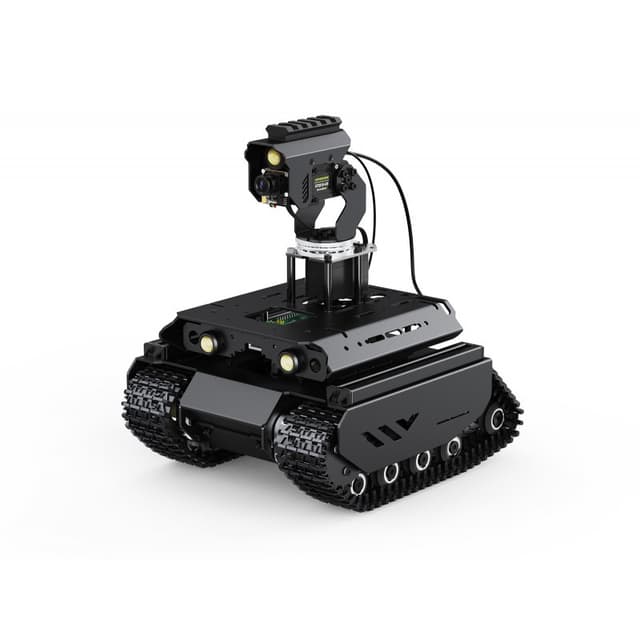
Waveshare UGV Beast
robotOpen-source ROS2 AI robot with tracked chassis, Raspberry Pi 4B/5, ESP32 sub-controller, 5MP camera with pan-tilt, IMU, and support for LiDAR expansion. Programmable via Python, OpenCV, and ROS2.
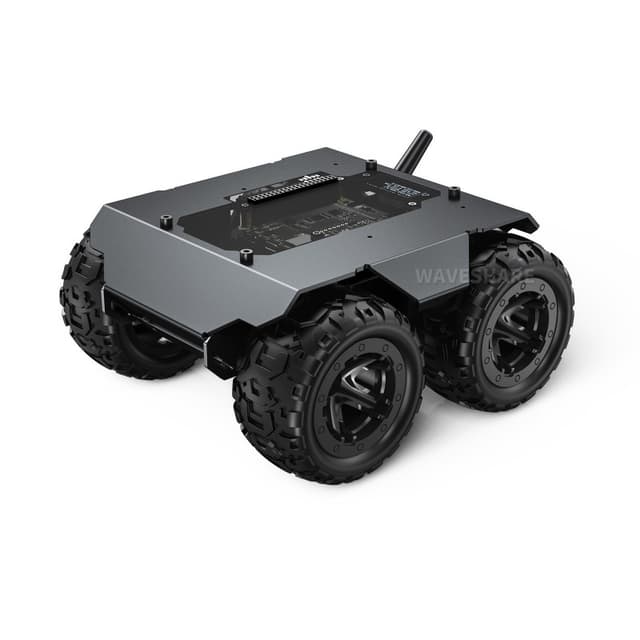
Waveshare WAVE ROVER
Robot PlatformFlexible 4WD mobile robot chassis with all-metal body, ESP32 controller, 0.91\" OLED, 9-axis IMU, 3S UPS power system, and open-source firmware. Supports Raspberry Pi and Jetson Nano as host computers
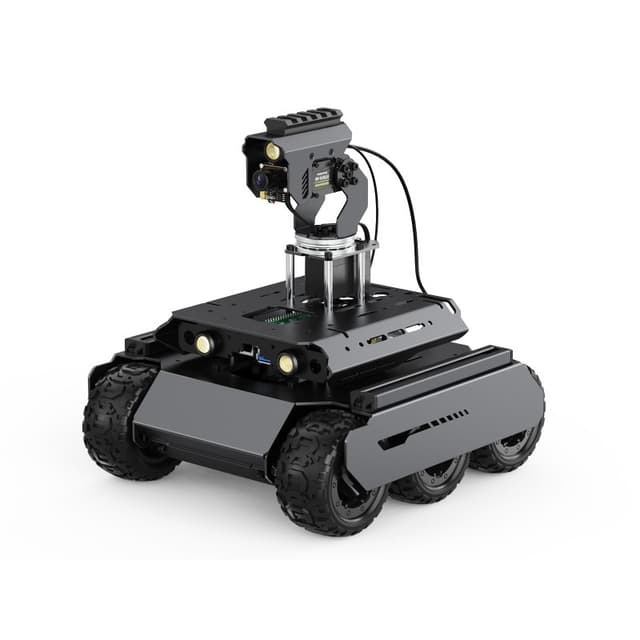
Waveshare UGV Rover
Robot PlatformOpen-source 6-wheel 4WD AI robot platform with dual-controller architecture (ESP32 + Raspberry Pi), computer vision, pan-tilt camera, ESP-NOW communication, and ROS2 support for robotics education and
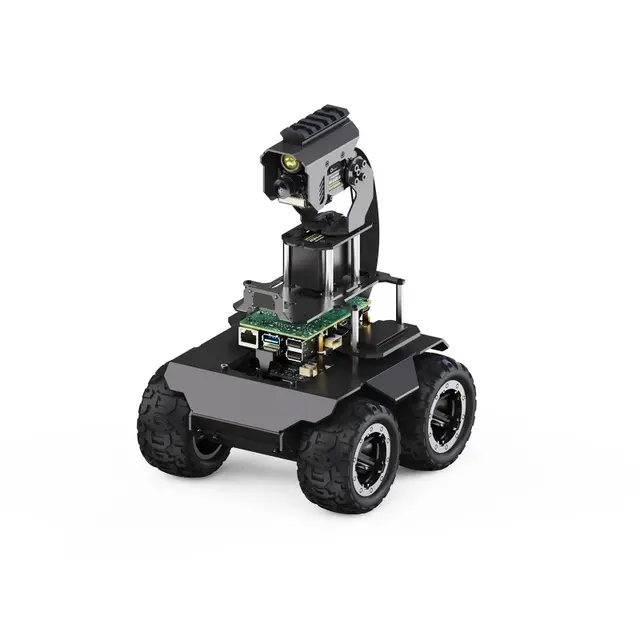
Waveshare RaspRover
Robot PlatformOpen-source 4WD AI robot with dual-controller architecture (ESP32 + Raspberry Pi), 5MP 160-degree camera, pan-tilt module, audio system, computer vision via OpenCV/MediaPipe, and ROS2 support for AI r
Get notified when new devices are added.
More to explore — popular traits shared by devices with Bus Interfaces: ESP-NOW.