Tutorialintermediate
ESP32 UWB Indoor Positioning System
Real-time indoor positioning demo using 3 ESP32 UWB modules (2 anchors + 1 tag) with trilateration, UDP data streaming, and Python-based position visualization on PC.
Boards:ESP32
Firmware:Arduino
Use Cases:IoT Prototyping
Overview
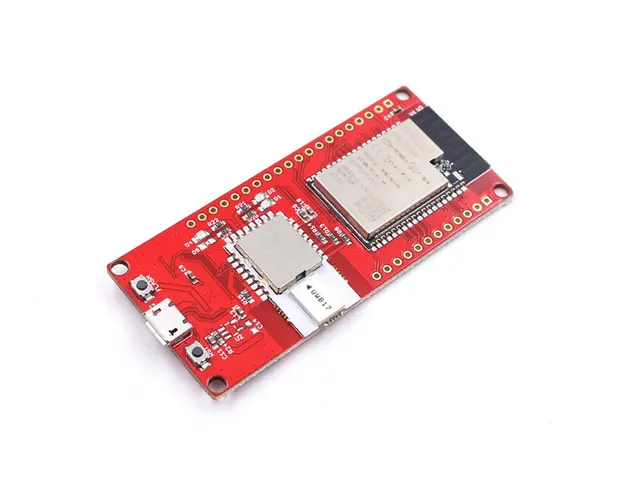
Official Makerfabs demo showing how to build a real-time indoor positioning system using three ESP32 UWB modules. Two modules act as stationary anchors while one serves as a mobile tag, with position data displayed graphically on a PC.
How It Works
- Two anchors are placed at known positions on opposite sides of the room
- The mobile tag measures distances to both anchors using double-sided two-way ranging
- Distance data is transmitted over WiFi via UDP protocol
- A Python script calculates the tag's 2D coordinates using the law of cosines
- Real-time position is displayed on a graphical interface
Hardware Required
- 3x ESP32 UWB modules (Makerfabs)
- Power banks or 5V power supplies for anchors
- PC running Python for visualization
Results
The system achieves approximately 10cm accuracy for indoor position tracking, with real-time coordinate updates as the tag moves through the space.