Build Guideintermediate
TinkerRTK ESPNow RTK Communication
Open-source Arduino project using ESP-NOW protocol for peer-to-peer RTK correction data exchange between TinkerNav boards, enabling infrastructure-free centimeter-level GPS positioning.
Boards:ESP32-S3RP2040
Firmware:Arduino
Use Cases:GPS TrackingRobotics
Overview
This project uses ESP-NOW, Espressif's connectionless WiFi communication protocol, to transmit RTK correction data between TinkerNav boards without requiring any WiFi infrastructure. ESP-NOW provides low-latency, peer-to-peer communication ideal for short-to-medium range RTK applications.
Key Features
- No WiFi Infrastructure Required: ESP-NOW enables direct board-to-board communication
- Low Latency: ESP-NOW protocol provides faster data transfer than traditional WiFi connections
- Simple Setup: Minimal configuration needed compared to WiFi network or NTRIP approaches
- Open Source: Full Arduino source code available on GitHub
Use Cases
- Quick RTK setup in the field without WiFi access
- Robotics applications requiring low-latency position corrections
- Temporary surveying deployments
- Educational demonstrations of RTK positioning
Hardware Required
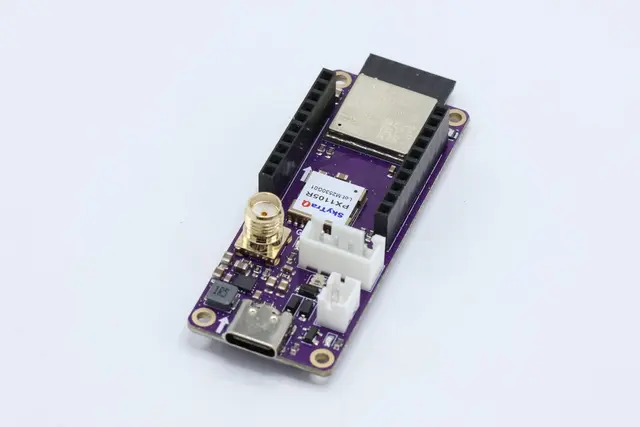
- 2x TinkerNav RTK GNSS base boards
- 2x GNSS antennas
- USB-C cables for programming
Getting Started
- Clone the repository from GitHub
- Open the base station and rover sketches in Arduino IDE
- Flash each TinkerNav board with the appropriate sketch
- Deploy outdoors with GNSS antennas and ground planes